
01June 2026 - September 2026
Shanghai Weiduo Technology Co., Ltd.
World Robot Contest Park Vision System
Computer Vision Software Engineering Intern / Shanghai, China
Engineered an accuracy-first YOLO and VLM vision system for autonomous park inspection in the World Robot Contest.
Architected a multi-stage inference pipeline combining YOLO detections with full-frame and cropped-image VLM review
Curated a 3,500+ image dataset across 14 classes and trained YOLO11m through a 200-epoch workflow
Deployed on NVIDIA Jetson AGX Thor with Docker, vLLM, and reusable Python/CLI integration
3,500+ images14 classes150+ tests2nd of 47 finalists
PythonPyTorchYOLO11mQwen2.5-VLvLLMDockerJetson AGX Thor
GitHub RepoOfficial Competition Footage
WRC / Park Scenario
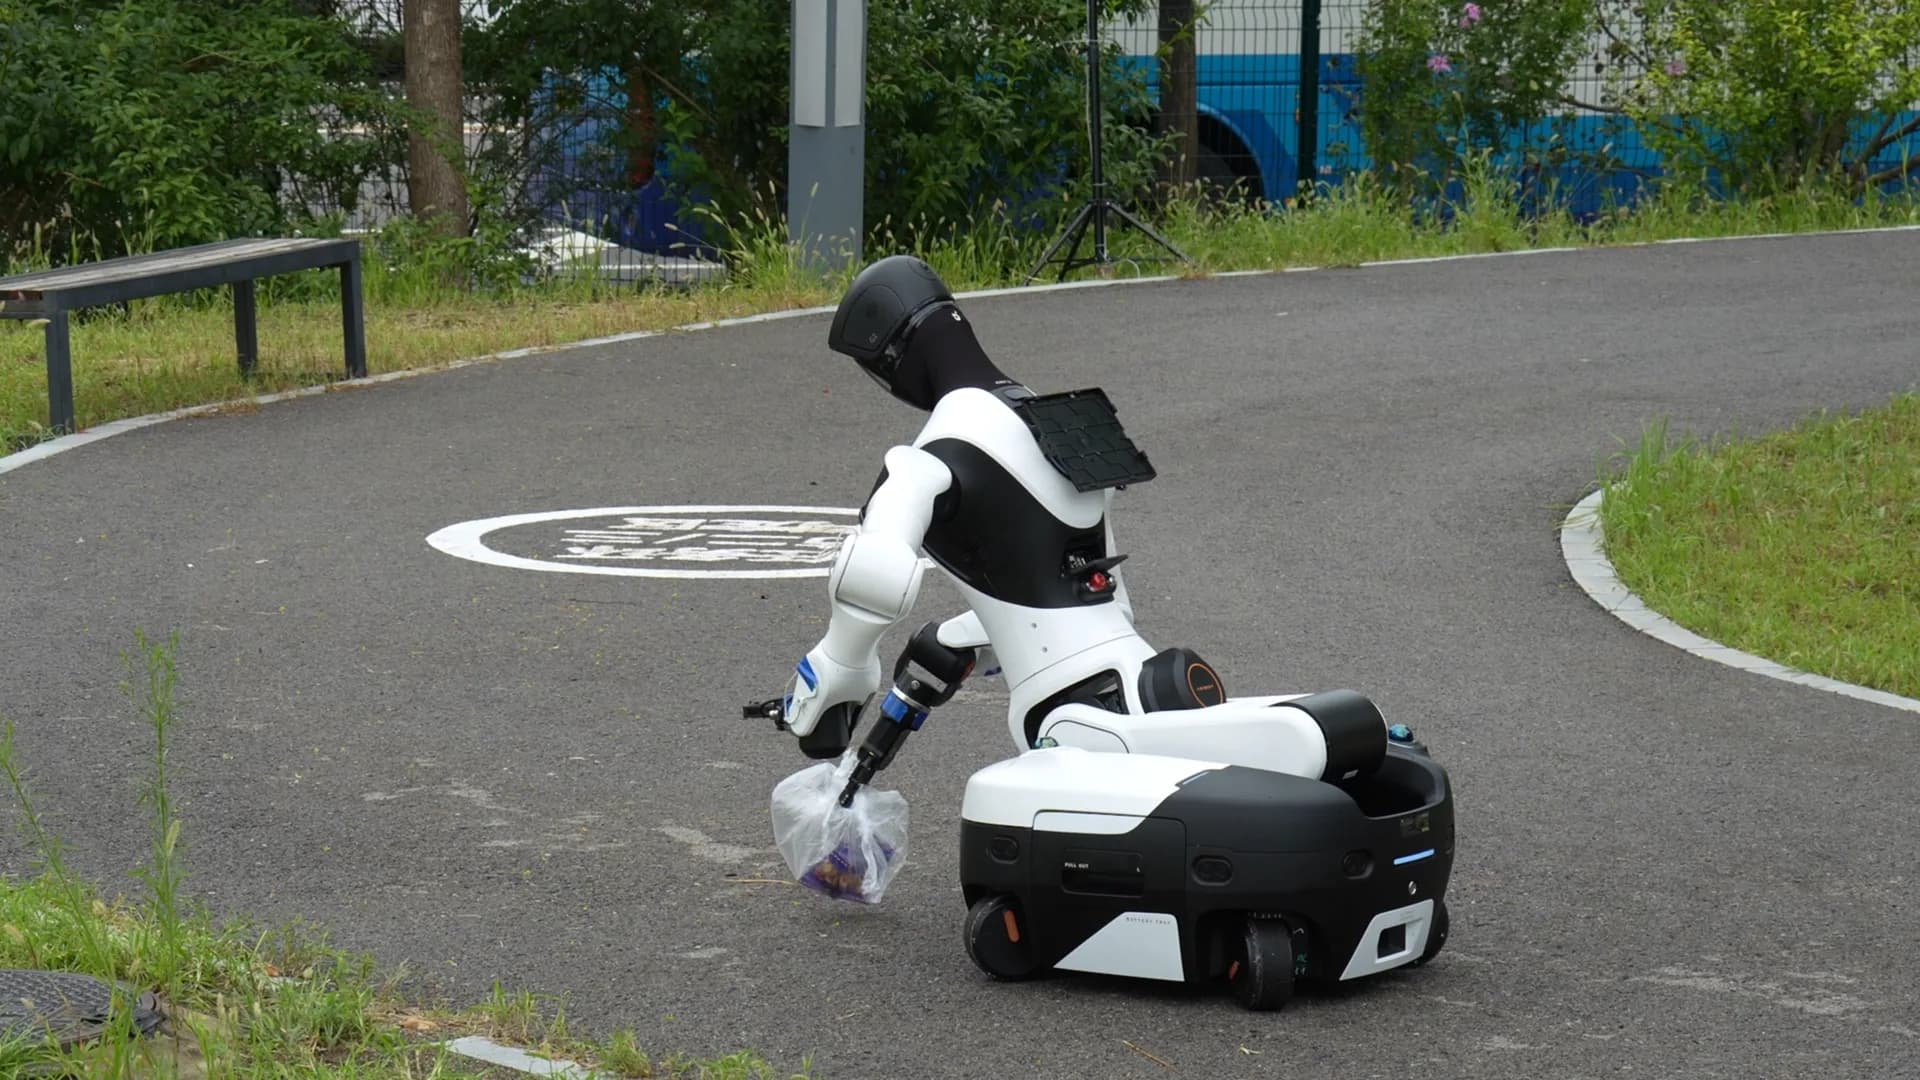
Litter Collection
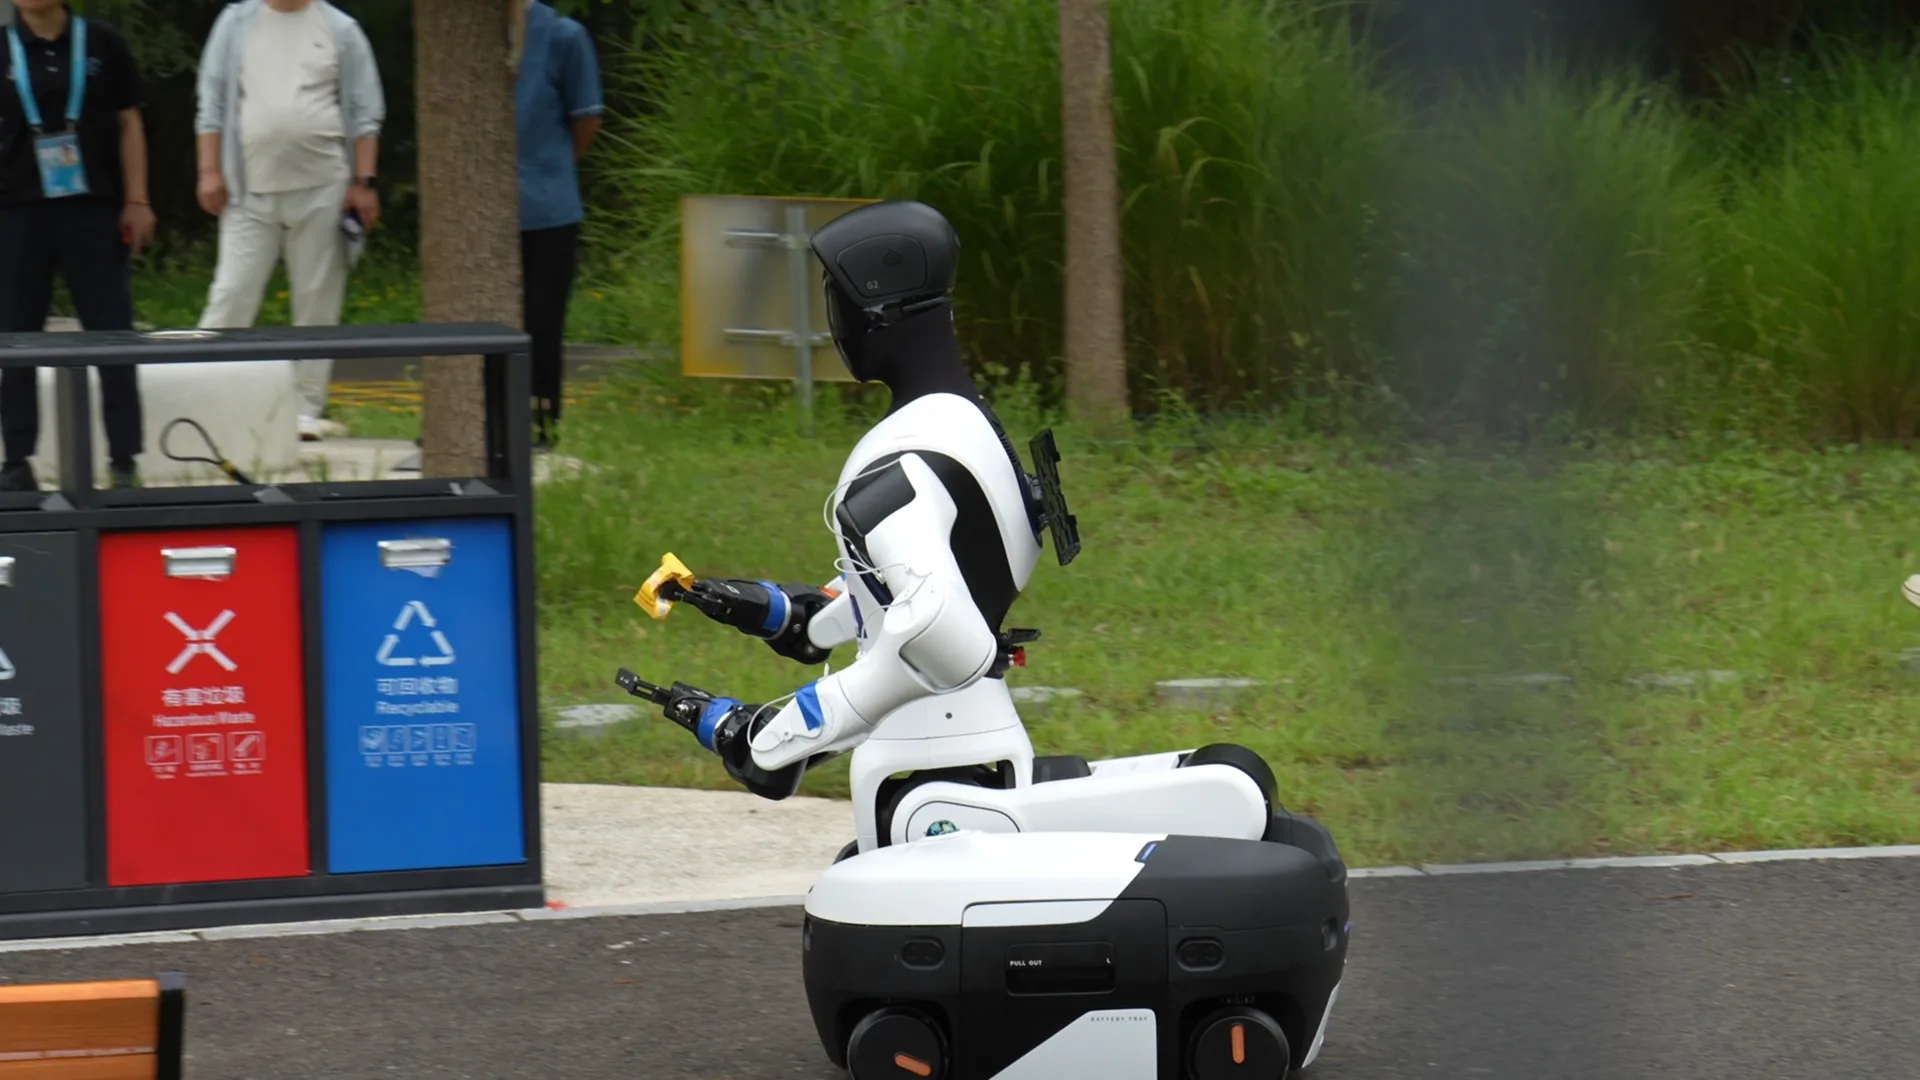
Waste Classification
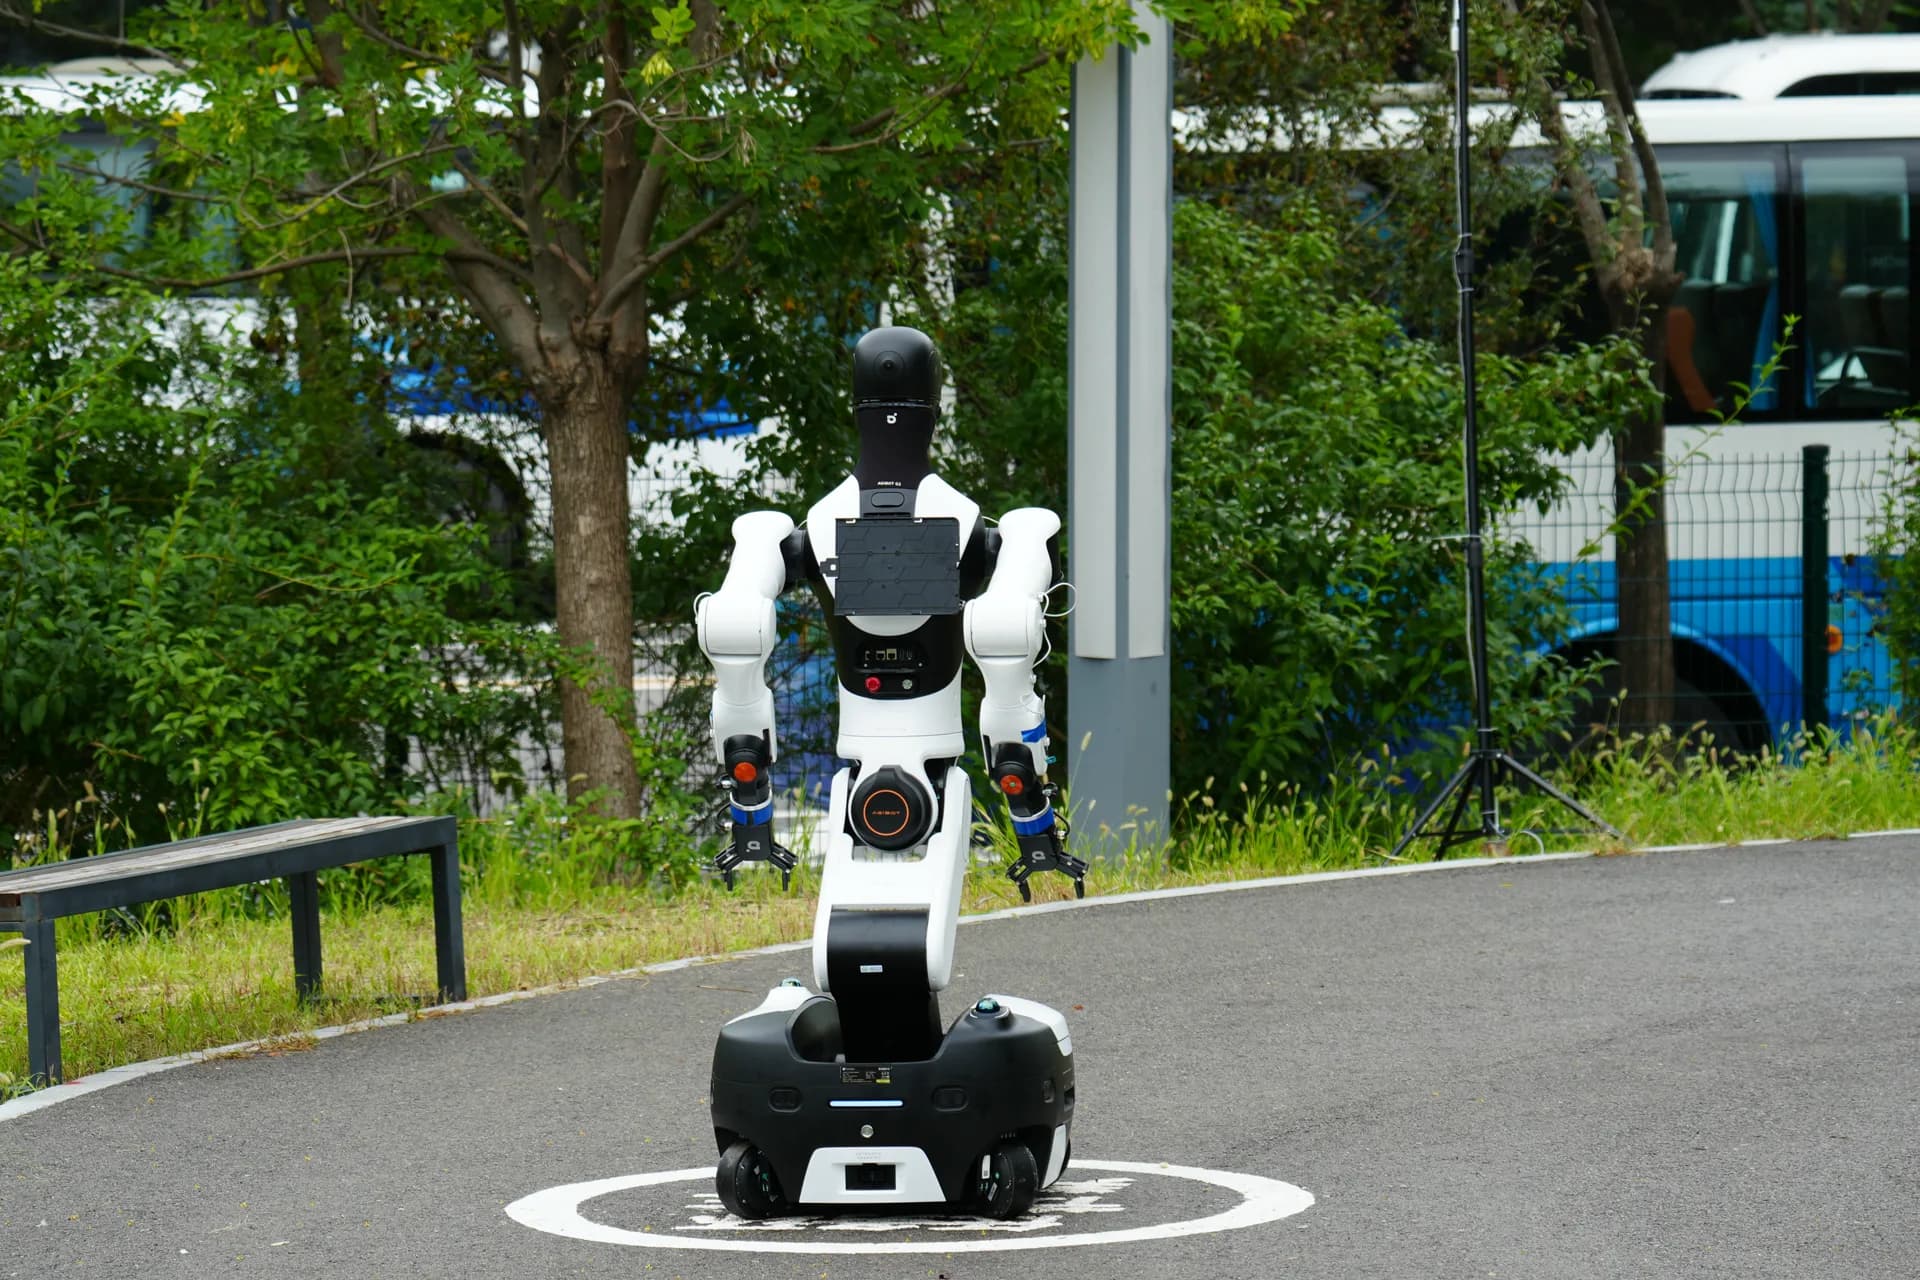
Autonomous Navigation
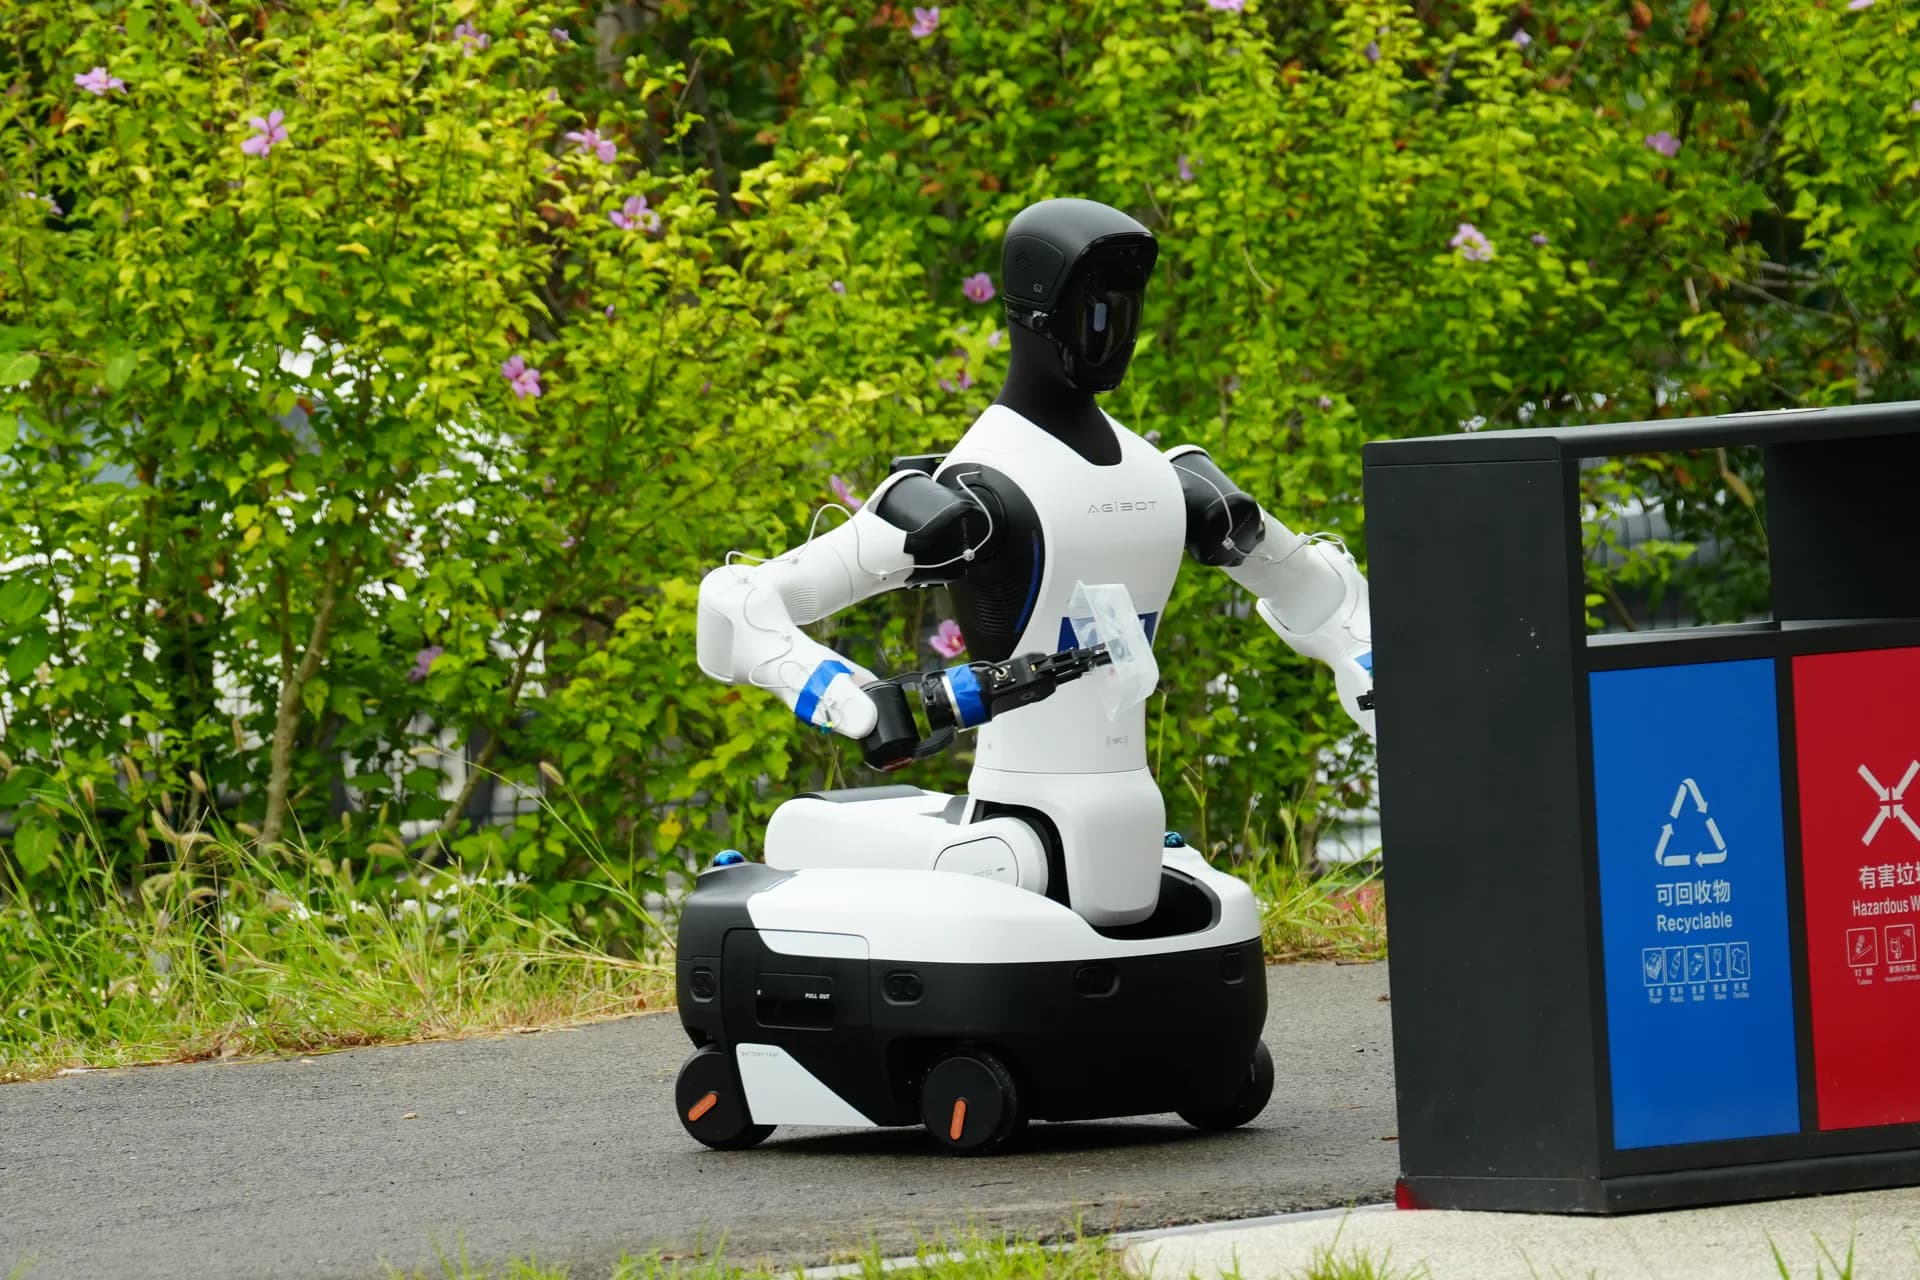
Waste Recognition